MP_Joint3D Class Reference

#include <MP_Joint3D.h>

Inheritance diagram for MP_Joint3D:
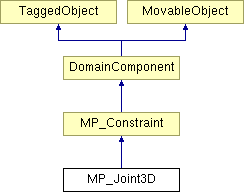
MP_Constraint DomainComponent TaggedObject MovableObject List of all members.

Public Member Functions

 MP_Joint3D ()
 MP_Joint3D (Domain *theDomain, int tag, int nodeRetain, int nodeConstr, int nodeRot, int Rotdof, int nodeDisp, int Dispdof, int LrgDsp=0)
 ~MP_Joint3D ()
int getNodeRetained (void) const
int getNodeConstrained (void) const
const ID & getConstrainedDOFs (void) const
const ID & getRetainedDOFs (void) const
int applyConstraint (double pseudoTime)
bool isTimeVarying (void) const
const Matrix & getConstraint (void)
void setDomain (Domain *theDomain)
int sendSelf (int commitTag, Channel &theChannel)
int recvSelf (int commitTag, Channel &theChannel, FEM_ObjectBroker &theBroker)
void Print (OPS_Stream &s, int flag=0)

Detailed Description

Definition at line 48 of file MP_Joint3D.h.


Constructor & Destructor Documentation

MP_Joint3D::MP_Joint3D (  ) 

Definition at line 42 of file MP_Joint3D.cpp.

MP_Joint3D::MP_Joint3D ( Domain *  theDomain,
int  tag,
int  nodeRetain,
int  nodeConstr,
int  nodeRot,
int  Rotdof,
int  nodeDisp,
int  Dispdof,
int  LrgDsp = 0 
)

MP_Joint3D::~MP_Joint3D (  ) 

Definition at line 212 of file MP_Joint3D.cpp.


Member Function Documentation

int MP_Joint3D::getNodeRetained ( void   )  const [virtual]

Reimplemented from MP_Constraint.

Definition at line 225 of file MP_Joint3D.cpp.

int MP_Joint3D::getNodeConstrained ( void   )  const [virtual]

Reimplemented from MP_Constraint.

Definition at line 232 of file MP_Joint3D.cpp.

const ID & MP_Joint3D::getConstrainedDOFs ( void   )  const [virtual]

Reimplemented from MP_Constraint.

Definition at line 240 of file MP_Joint3D.cpp.

References exit(), and opserr.

const ID & MP_Joint3D::getRetainedDOFs ( void   )  const [virtual]

Reimplemented from MP_Constraint.

Definition at line 254 of file MP_Joint3D.cpp.

References exit(), and opserr.

int MP_Joint3D::applyConstraint ( double  pseudoTime  )  [virtual]

Reimplemented from MP_Constraint.

Definition at line 268 of file MP_Joint3D.cpp.

References Node::getCrds(), Node::getDisp(), Vector::Norm(), and Matrix::Zero().

bool MP_Joint3D::isTimeVarying ( void   )  const [virtual]

Reimplemented from MP_Constraint.

Definition at line 326 of file MP_Joint3D.cpp.

const Matrix & MP_Joint3D::getConstraint ( void   )  [virtual]

Reimplemented from MP_Constraint.

Definition at line 347 of file MP_Joint3D.cpp.

References exit(), Node::getCrds(), Node::getTrialDisp(), Vector::Norm(), opserr, and Node::setTrialDisp().

void MP_Joint3D::setDomain ( Domain *  theDomain  )  [virtual]

Reimplemented from DomainComponent.

Definition at line 413 of file MP_Joint3D.cpp.

References Domain::getNode(), and DomainComponent::setDomain().

int MP_Joint3D::sendSelf ( int  commitTag,
Channel &  theChannel 
) [virtual]

Reimplemented from MP_Constraint.

Definition at line 334 of file MP_Joint3D.cpp.

int MP_Joint3D::recvSelf ( int  commitTag,
Channel &  theChannel,
FEM_ObjectBroker &  theBroker 
) [virtual]

Reimplemented from MP_Constraint.

Definition at line 340 of file MP_Joint3D.cpp.

void MP_Joint3D::Print ( OPS_Stream &  s,
int  flag = 0 
) [virtual]

Reimplemented from MP_Constraint.

Definition at line 396 of file MP_Joint3D.cpp.

References TaggedObject::getTag().


The documentation for this class was generated from the following files:

Generated on Mon Oct 23 15:05:45 2006 for OpenSees by doxygen 1.5.0